Sfoglia categorie
Esplora
Fiverr Pro
Italiano
$
USD
UAV Robotics PCB Design STM32 Flight Controller and Embedded Systems
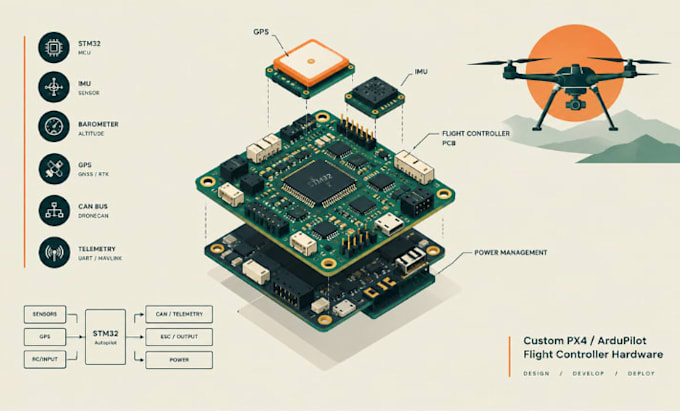
I design custom PX4 and ArduPilot autopilot PCBs for UAVs, VTOL aircraft, mapping drones, autonomous vehicles and industrial flight systems.
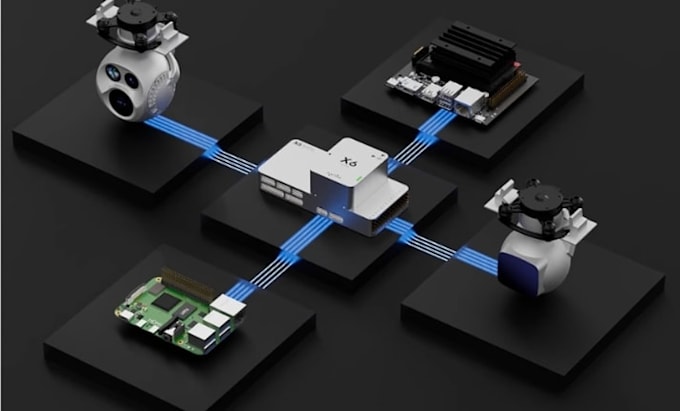
Hardware can include STM32F4, F7 or H7 MCUs, Pixhawk compatible architecture, IMU, barometer, magnetometer, GPS GNSS, RTK GPS, CAN DroneCAN, telemetry UARTs, RC interfaces, PWM outputs, USB and companion computer connectivity.
I focus on reliable flight control hardware with low noise sensor power, sensor isolation, battery voltage and current monitoring, power protection, EMI conscious routing and practical connector placement. Advanced designs can support redundant IMUs, dual barometers, multiple CAN buses, GPS ports and telemetry interfaces.
Deliverables include architecture, schematic capture, component selection, PCB layout, BOM, Gerber, drill files, Pick and Place, 3D PCB, DFM checks and source files.
I can design hardware for PX4, ArduPilot, Pixhawk compatible systems, VTOL, fixed wing, multirotor, mapping and industrial UAV applications. Whether you have an existing reference design, schematic or only a hardware concept, I can develop the electronics around your requirements.
Can you design a PX4 flight controller PCB?
Yes. I can design custom PX4 flight controller hardware using STM32F4, F7 or H7 processors with IMU, barometer, GPS, CAN, telemetry, RC and PWM interfaces.
Can you design an ArduPilot autopilot PCB?
Yes. I can develop ArduPilot compatible hardware with STM32, IMU, GPS or RTK GPS, CAN DroneCAN, telemetry, power monitoring and appropriate peripheral interfaces.
Can you make a Pixhawk compatible PCB?
Yes. I can design hardware around Pixhawk compatible architecture and interfaces. Compatibility requirements should be defined from the target Pixhawk standard, firmware board configuration and required peripherals.
Can you integrate IMU, barometer and GPS?
Yes. I can integrate IMU, accelerometer, gyroscope, magnetometer, barometer and GPS/GNSS interfaces with appropriate buses, power domains and layout considerations.
Can you add DroneCAN or CAN bus?
Yes. I can include CAN or DroneCAN interfaces for GPS, ESCs, sensors and other UAV peripherals, including appropriate transceiver and protection circuitry.
Can you design RTK GPS and telemetry interfaces?
Yes. Hardware can include dedicated GPS/GNSS, RTK, UART telemetry and other communication interfaces depending on the vehicle architecture and selected modules.
Can you design redundant IMU and sensor power systems?
Yes. Advanced autopilot hardware can include multiple IMUs, redundant barometers, separate sensor buses and independent or isolated power domains where the application requires them.
Do you provide manufacturing files?
Yes. Depending on the package, deliverables can include schematic, PCB source, BOM, Gerber, drill, Pick and Place, 3D PCB data and DFM-oriented manufacturing documentation.
Can you design boards for VTOL or fixed wing UAVs?
Yes. I can develop flight-control hardware for multirotors, fixed wing aircraft, VTOL platforms, mapping systems, autonomous vehicles and industrial UAV applications.